
-
Research Highlight
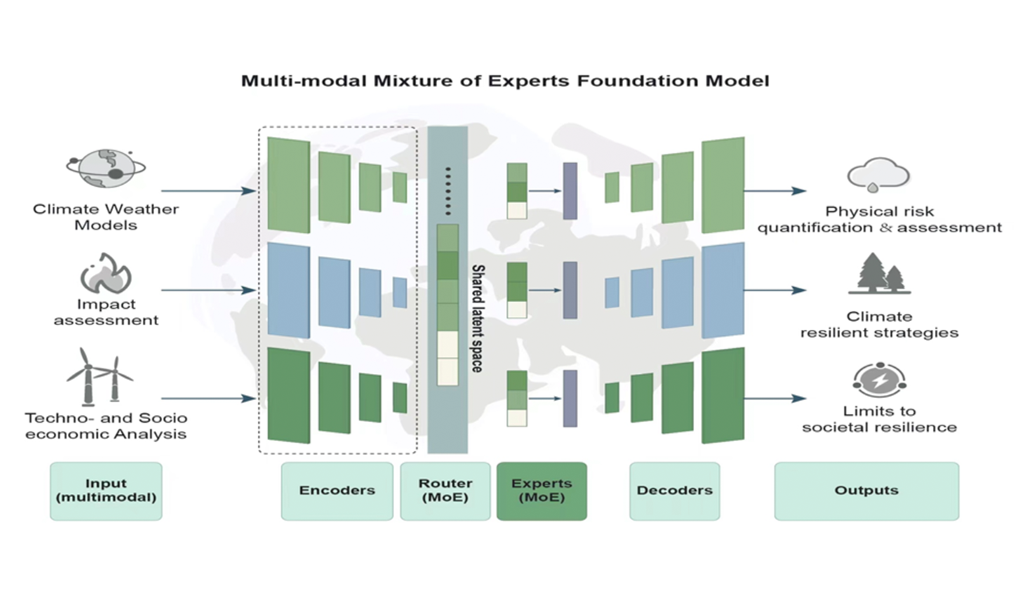
Artificial intelligence to support cross-disciplinary climate change research
Professor McJeon’s team published a commentary for an AI foundation-model architecture that integrates climate, impact, and socioeconomic analysis for decision support. ...read more
-
Research Highlight
Beyond the Bell Curve Towards Safer, Faster Control for Autonomous Systems Under Real-World Uncertainty
Real-world disturbances do not always follow Gaussian distributions. The creates a challenging trade-off for safety-critical autonomous control: simple risk models can be misleading, while more flexible alternatives can be too computationally demanding for real-time use. Professor Hyo-Sang Shin's team at KAIST developed Spectral-IRA, combining non-Gaussian uncertainty propagation, data-driven calibration, and adaptive risk allocation to turn nonlinear probabilistic safety constraints into a tractable convex control problem. Theoretical analysis and simulations show that Spectral-IRA can keep risk within prescribed limits while remaining fast enough for real-time control. ...read more

-
Research Highlight
High-titer, antibiotic-free, pilot-scale production of 1,3-propanediol by engineered Corynebacterium
Professor Lee’s group developed microbial cell factories for high-level 1,3-PDO production, with scalability confirmed at 300-L pilot scale. ...read more

-
Research Highlight
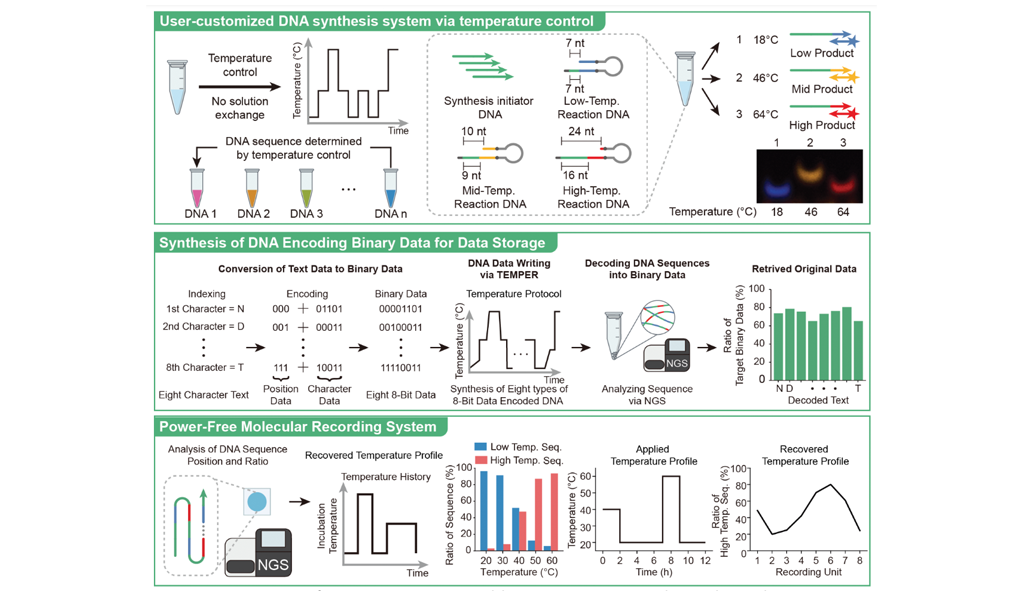
TEMPER Enables Programmable One-Pot DNA Synthesis through Temperature Control
Professor Yeongjae Choi’s group developed TEMPER, a one-pot DNA synthesis platform programmed solely by temperature without repeated solution exchange ...read more
-
Research Highlight
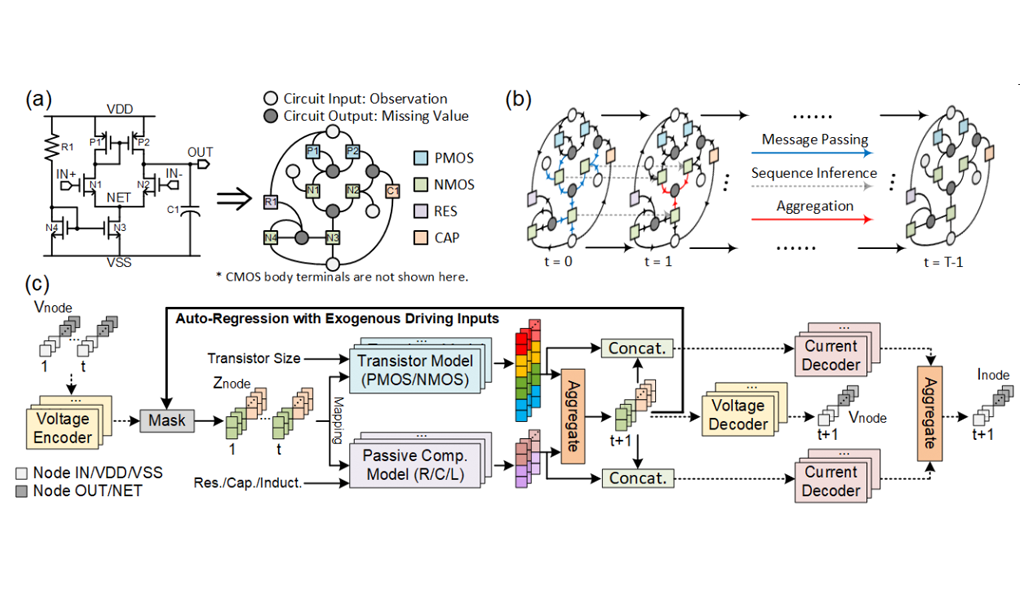
UNCHARTED: A Universal ML-based Framework for Circuit Simulation and Inverse Design
Professor Jung’s group developed UNCHARTED, an AI framework that learns component-level circuit behavior for fast transient simulation and inverse design. ...read more
-
Research Highlight
A 14.4-Gb/s 7.3-pJ/b Universal Vision Transformer OFDM Channel Estimation Processor for B5G/6G Communication Systems
Professor Lee’s team developed UniC-Vision, the first silicon-proven Vision Transformer channel estimation processor for B5G/6G AI-RAN systems. ...read more

-
Research Highlight
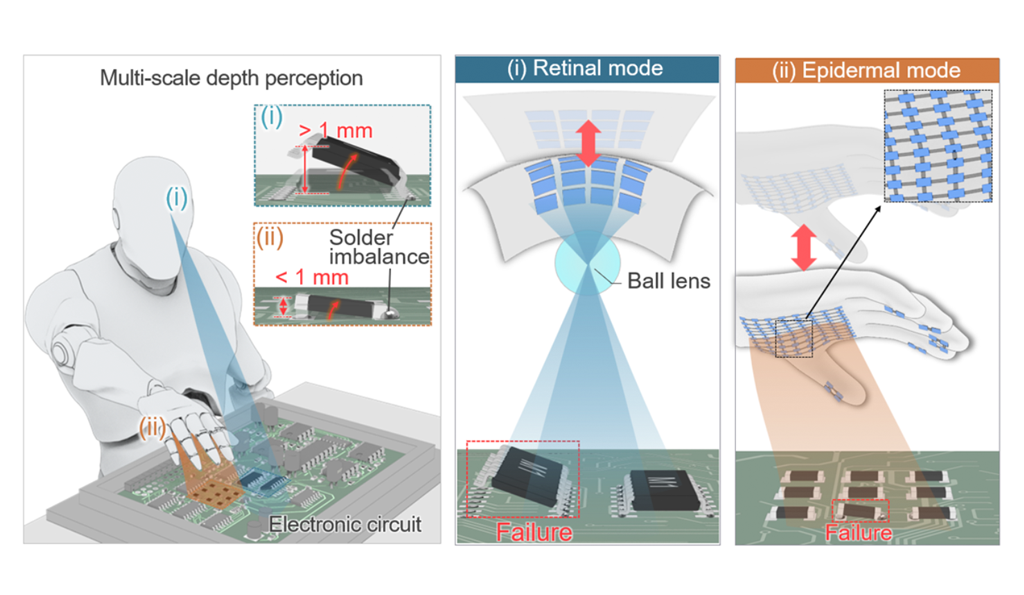
Stretchable High-Density Silicon–Liquid Metal Electronics for Robotic Visions
Professor Song’s group has developed a robotic vision system combining varifocal and lens-free imaging, enabling multiscale visual acquisition and depth sensing. ...read more
-
Research Highlight
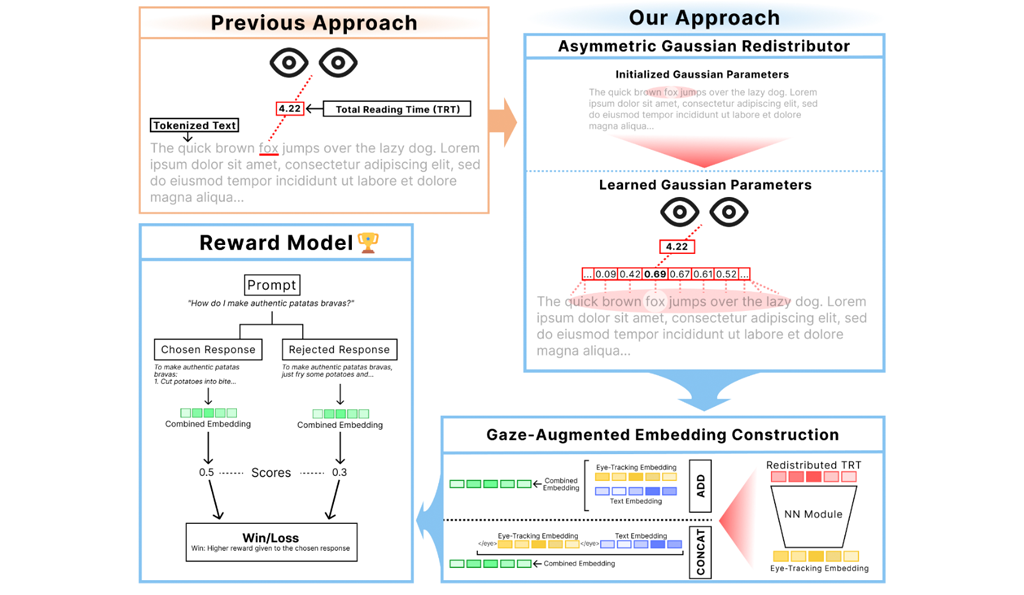
Human-Like Visual Attention Improves Gaze-Augmented Reward Modeling for Large Language Models
Professor Sang Ho Lee’s group developed a gaze-augmented reward modeling approach for LLMs that incorporates a psychologically grounded account of visual attention. The new approach improved human preference prediction across tested LLM models. ...read more
-
Research Highlight Top Story
Making End-to-End Driving Robust to Camera Viewpoint Changes
Prof. Kuk-Jin Yoon’s group at KAIST has developed VR-Drive, a new end-to-end autonomous driving framework that remains robust even when camera viewpoints change across vehicles and sensor setups. ...read more

-
Research Highlight
Customized Solver for Onboard Real-Time Convex Optimization in Autonomous Systems
Prof. Chang-Hun Lee’s group has developed a customized convex optimization solver enabling real-time onboard optimization for guidance and control in autonomous systems. ...read more

291 Daehak-ro Yuseong-gu Daejeon, 34141, Republic of Korea
Partnered with KAIST Breakthroughs and KAIST Compass